Research
Please find below the full list of papers, that I have been involved with.
Journals
|
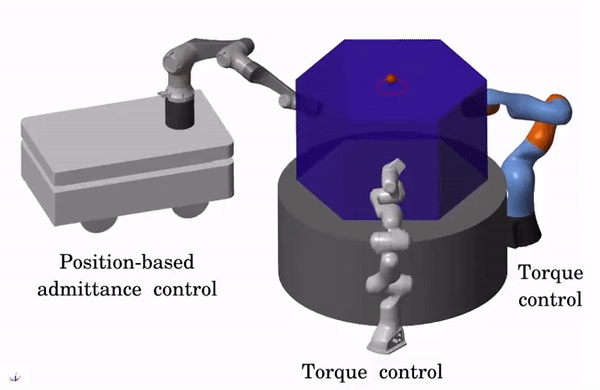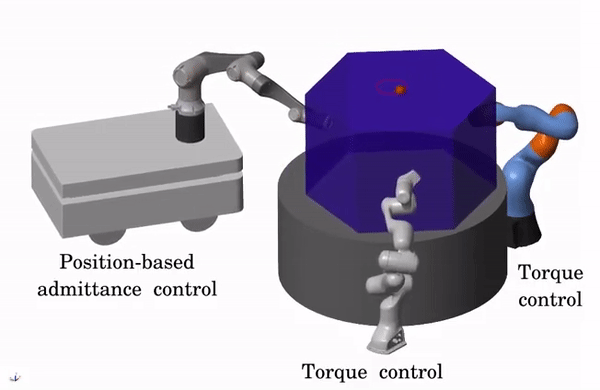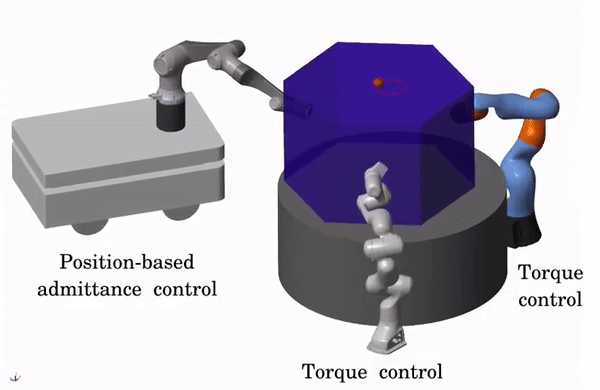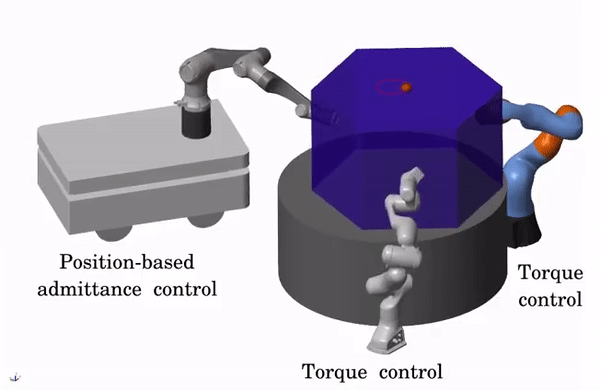
Set-based State Estimation with Probabilistic Consistency Guarantee under Epistemic Uncertainty. Li, S. * , Stouraitis, T. * , Gienger, M., Vijayakumar, S. and Shah, A. J. IEEE Robotics and Automation Letters (RA-L), 2022, IEEE-link, pdf, video, MIT news, MIT Instagram — |
|
Decentralized ability-aware adaptive control for multi-robot collaborative manipulation. Yan, L., Stouraitis, T., and Vijayakumar, S. IEEE Robotics and Automation Letters (RA-L), 2021, IEEE-link, pdf, video — |
|
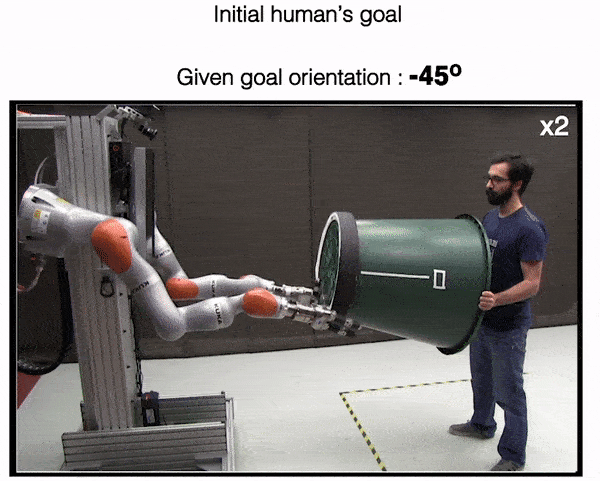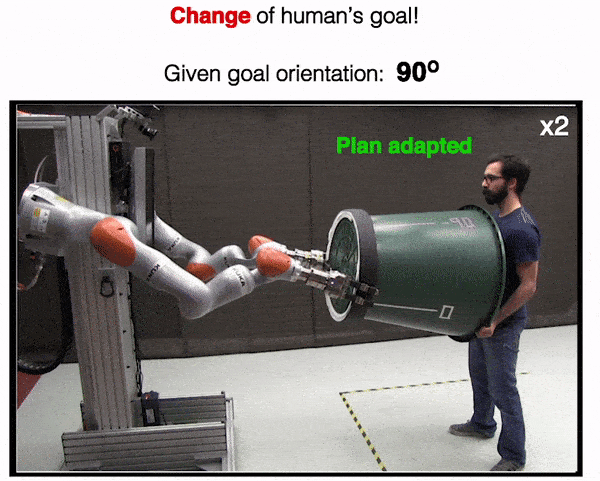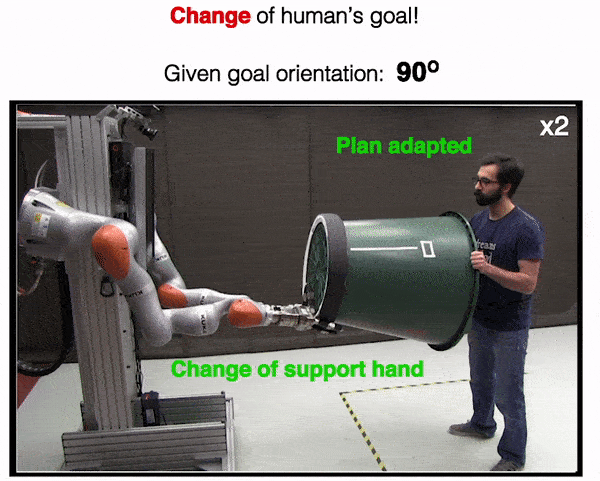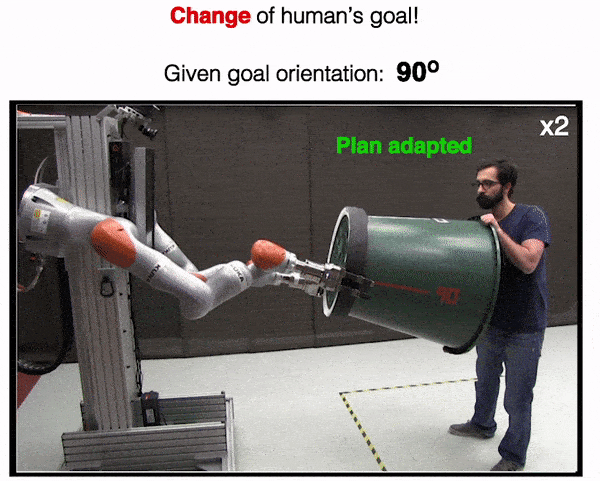
Online Hybrid Motion Planning for Dyadic Collaborative Manipulation via Bilevel Optimization. Stouraitis, T., Chatzinikolaidis, I., Gienger, M., and Vijayakumar, S. IEEE Transactions on Robotics (T-RO), 2020 (invited), IEEE-link, pdf, video 2020 TC on Model-Based Optimization for Robotics Best Paper Award Finalist, link |
Conferences
|
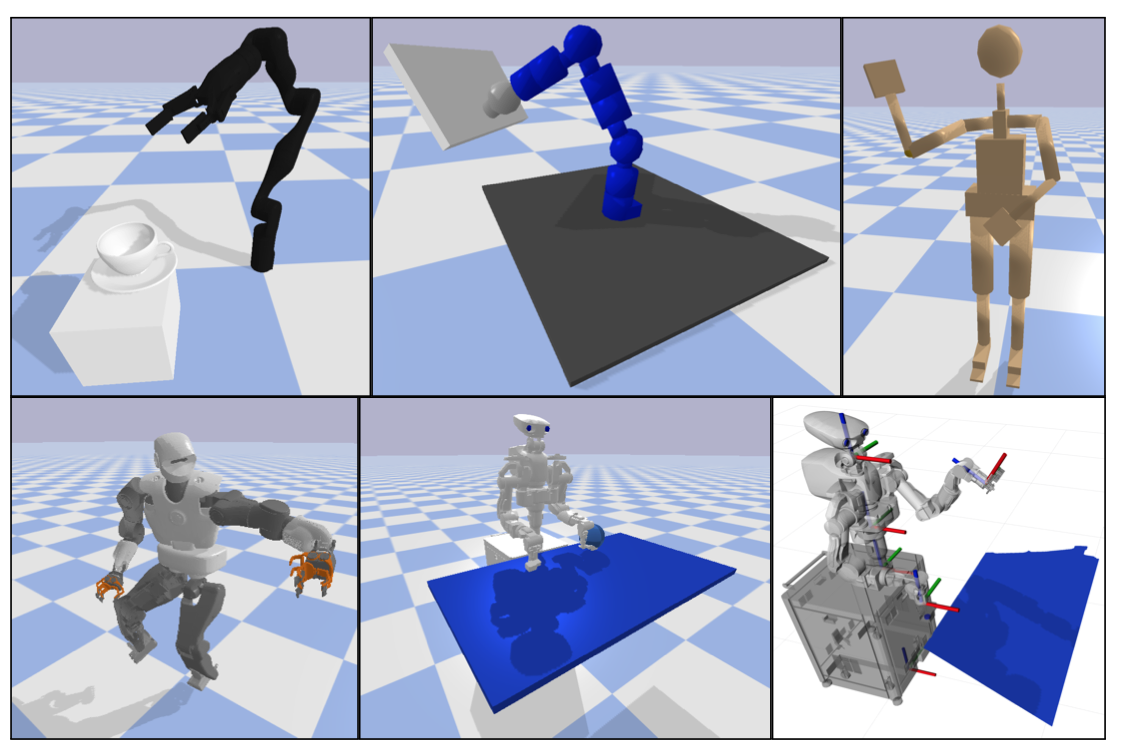
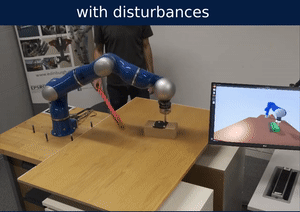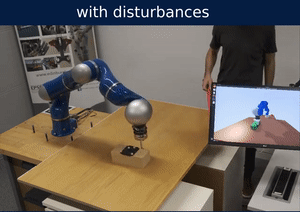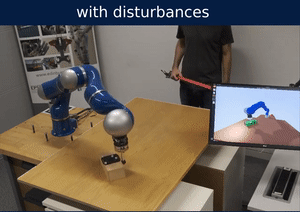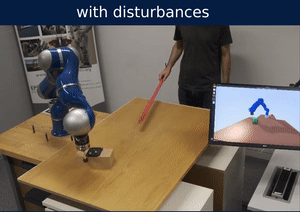
ROS PyBullet Interface: A Framework for Reliable Contact Simulation and Human-Robot Interaction. Mower, C., Stouraitis, T., Moura, J., Rauch, C., Yan, Lei., Behabadi, N., Gienger, M., Vercauteren, T., Bergeles, C., and Vijayakumar, S., Conference on Robot Learning (CoRL), 2022, To appear, pdf — |
|
Non-prehensile Planar Manipulation via Trajectory Optimization with Complementarity Constraints. Moura, J., Stouraitis, T., and Vijayakumar, S. IEEE International Conference on Robotics and Automation (ICRA), 2022, IEEE-link, pdf, video — |
|
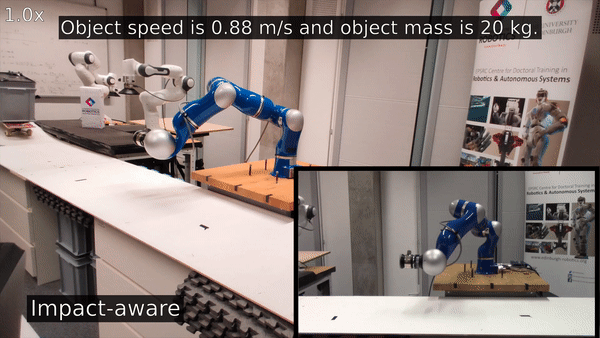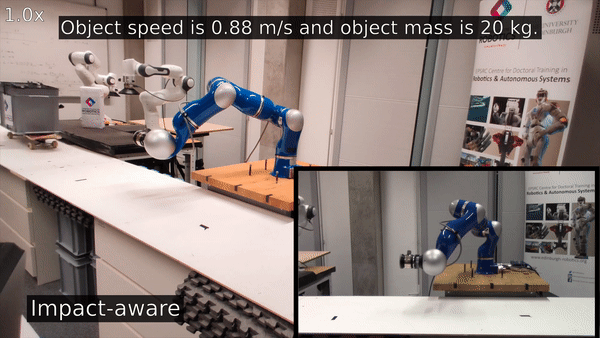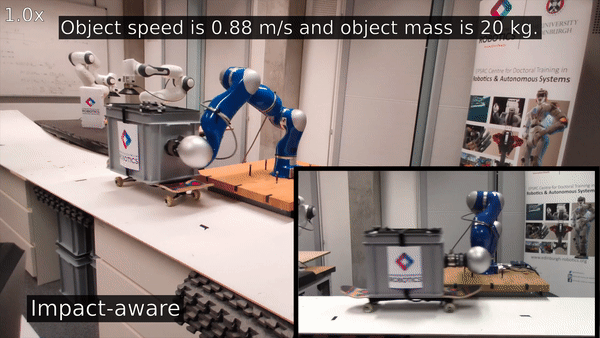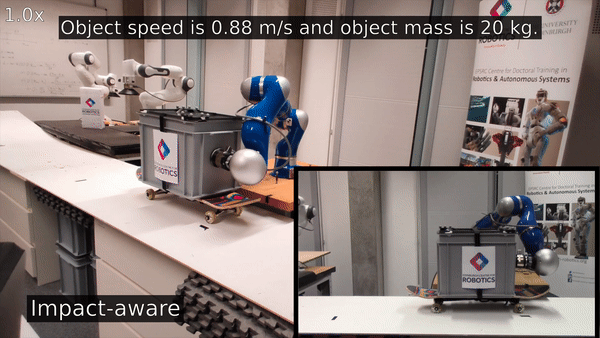
Multi-modal Trajectory Optimization for Impact-aware Manipulation. Stouraitis, T. * , Yan, L. * , Moura J., Gienger, M., and Vijayakumar, S. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020, IEEE-link, pdf, video — |
|
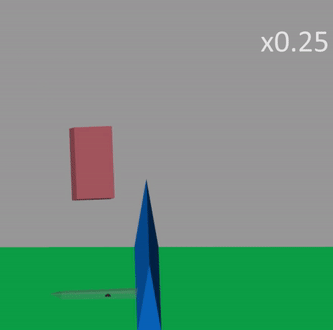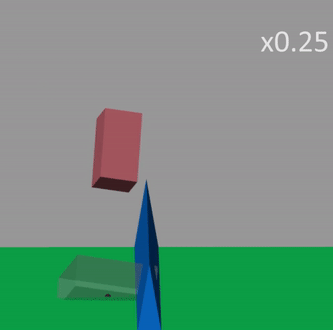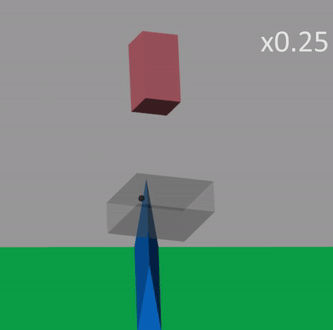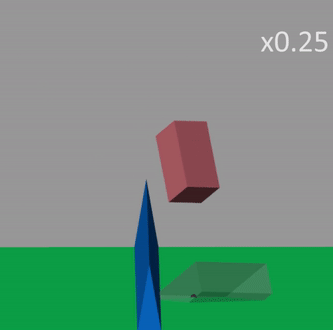
Dyadic collaborative Manipulation through Hybrid Trajectory Optimization. Stouraitis, T., Chatzinikolaidis, I., Gienger, M., and Vijayakumar, S. Conference on Robot Learning (CoRL), 2018, PMLR-link, pdf, video Best System Paper Award Finalist — |
|
Nonlinear Optimization using Discrete Variational Mechanics for Dynamic Maneuvers of a 3D One-Leg Hopper. Chatzinikolaidis, I., Stouraitis, T., Vijayakumar, S. and Li, Z. IEEE-RAS International Conference on Humanoid Robots (Humanoids), 2018, link — |
|
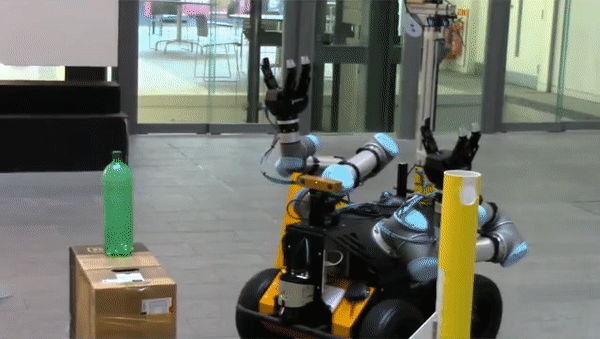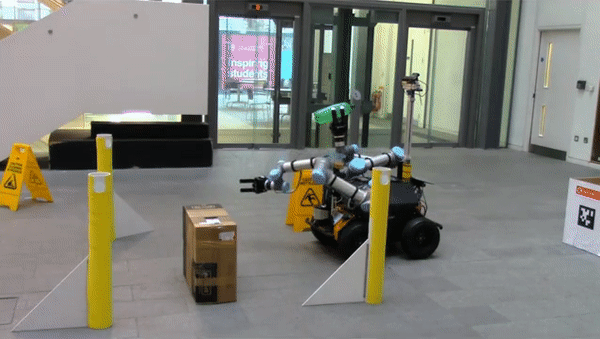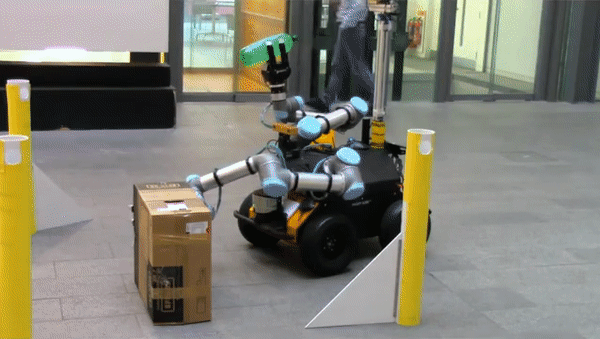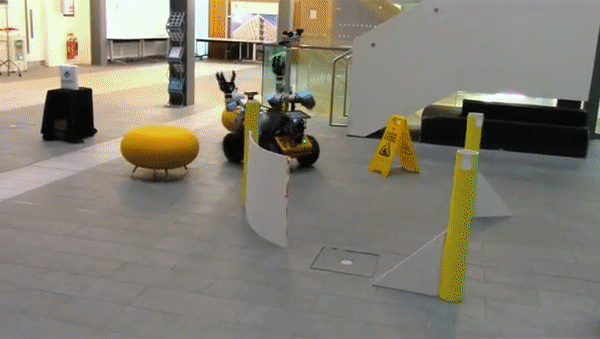
Robust shared autonomy for mobile manipulation with continuous scene monitoring. Merkt, W., Yang, Y., Stouraitis, T., Mower, C. E., Fallon, M., and Vijayakumar, S. IEEE Int. Conf. on Automation Science and Engineering (CASE), 2017, pdf, video, First Prize at Robots for Resilient Infrastructure Challenge 2017, Leeds TV — |
|
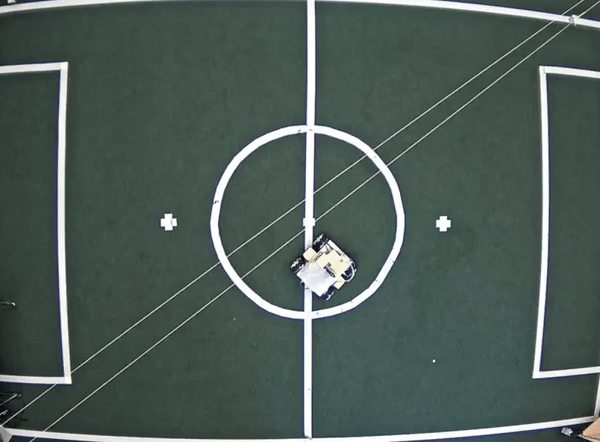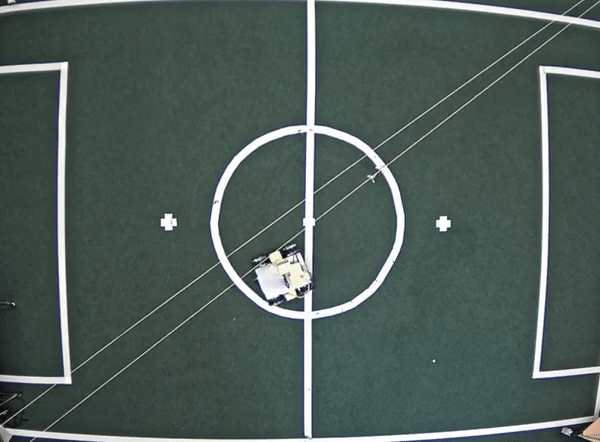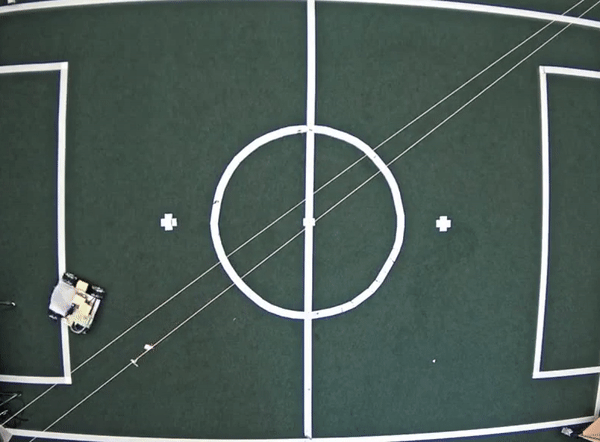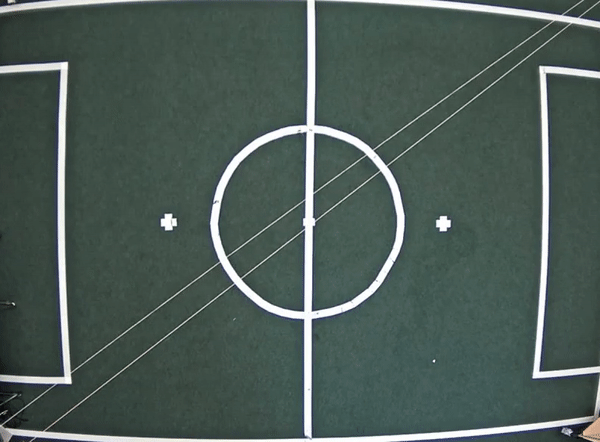
Predator Evasion by a Robocrab. Stouraitis, T., Gkanias, E., Hemmi, J. M., and Webb, B. In Conference on Biomimetic and Biohybrid Systems (Living Machines), 2017, link — |
|
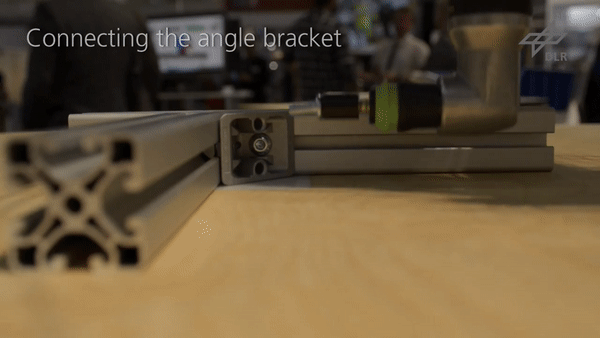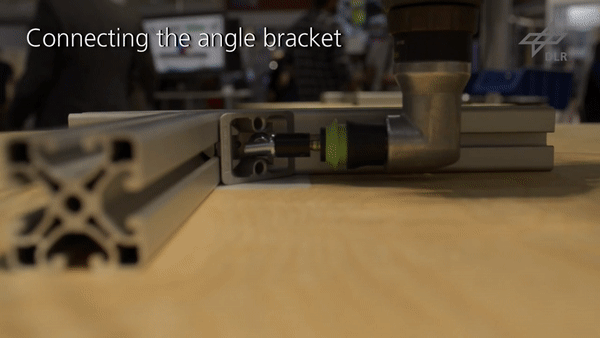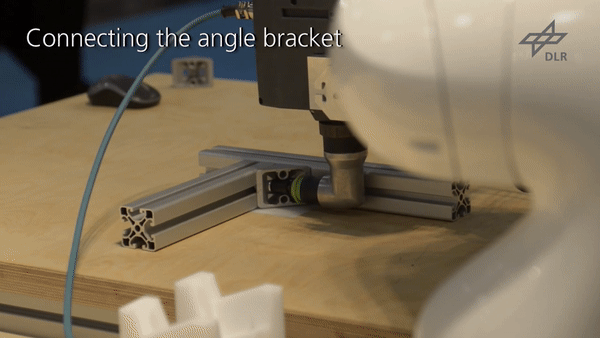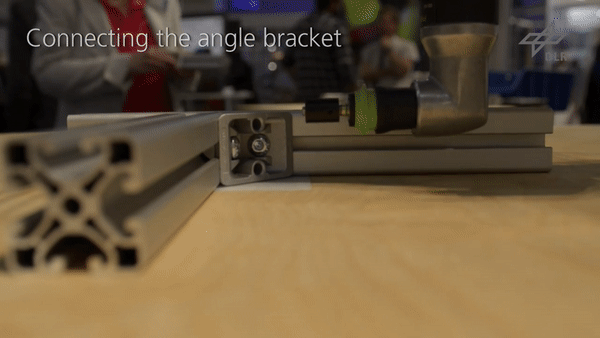
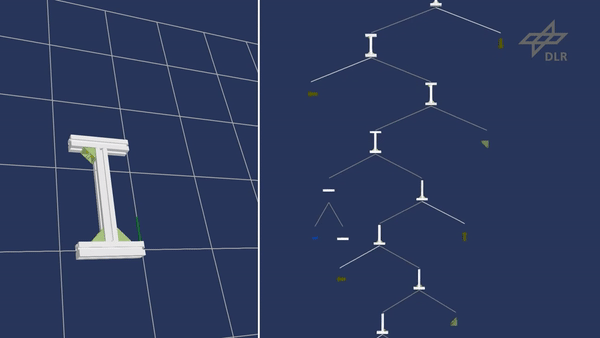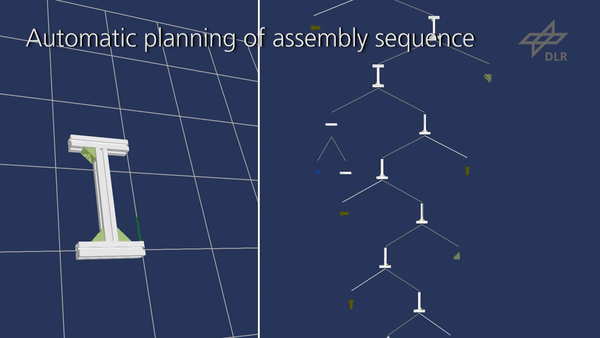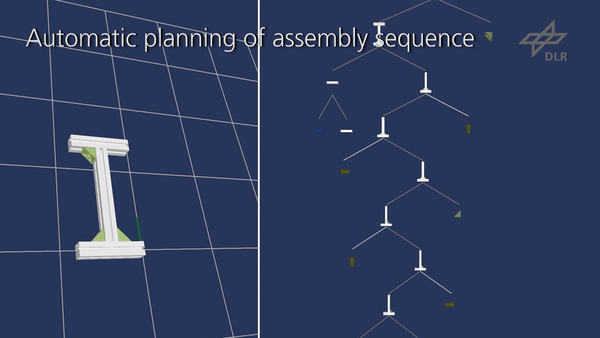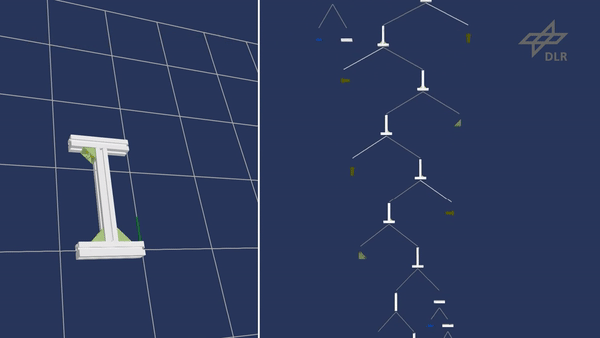
A Complete Automated Chain for Flexible Assembly using Recognition, Planning and Sensor-Based Execution. Nottensteiner, K., Bodenmueller, T., Kassecker, M., Roa, M. A., Stemmer, A., Stouraitis, T., Seidel, D. and Thomas, U. 47st International Symposium on Robotics (ISR), 2016, link, video — |
|
Flexible Assembly through Planning - Assembly Sequence Planning with the Integration of Grasp Planning. Thomas, U., Stouraitis, T., and Roa, M.A. IEEE Int. Conf. on Automation Science and Engineering (CASE), 2015, link — |
|
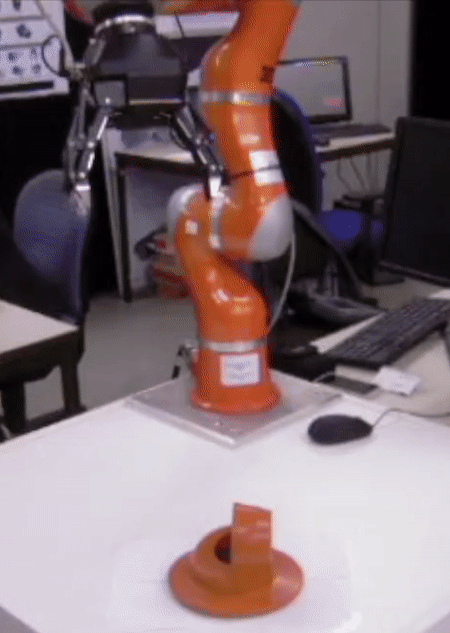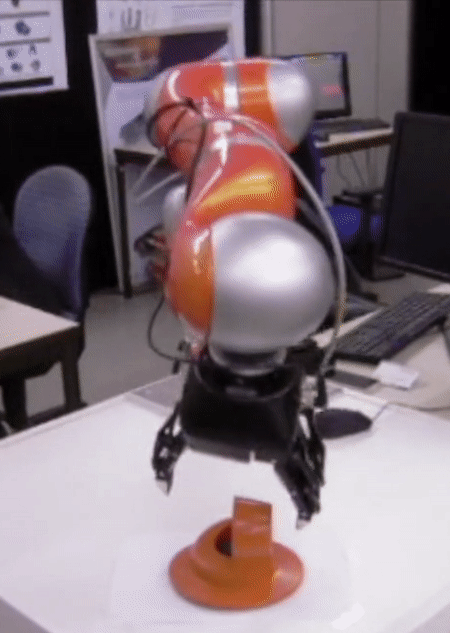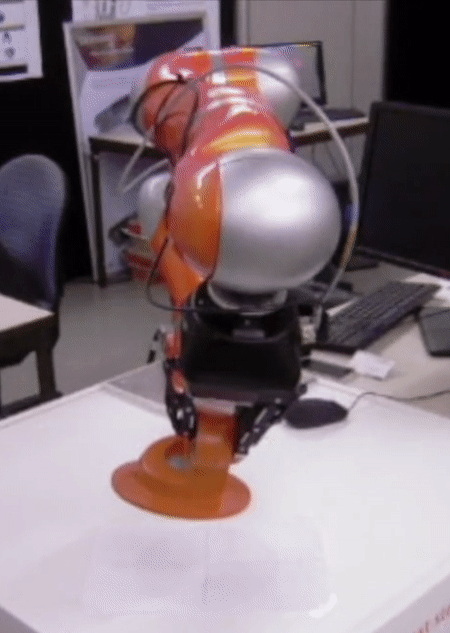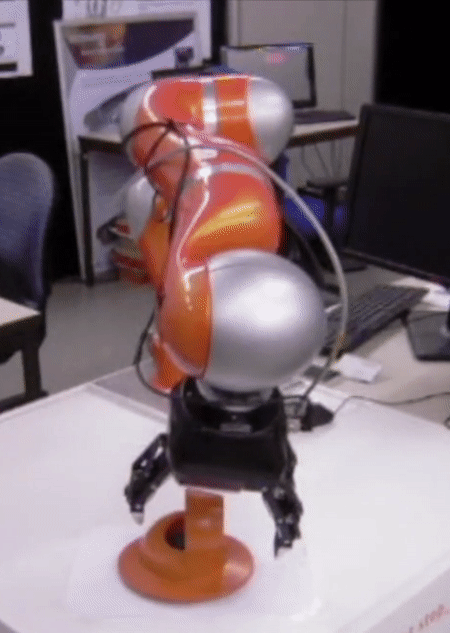
Functional power grasps transferred through contact warping.
Stouraitis, T., Hillenbrand, U., and Roa, M.A. IEEE International Conference on Robotics and Automation (ICRA), 2015, link — |
|
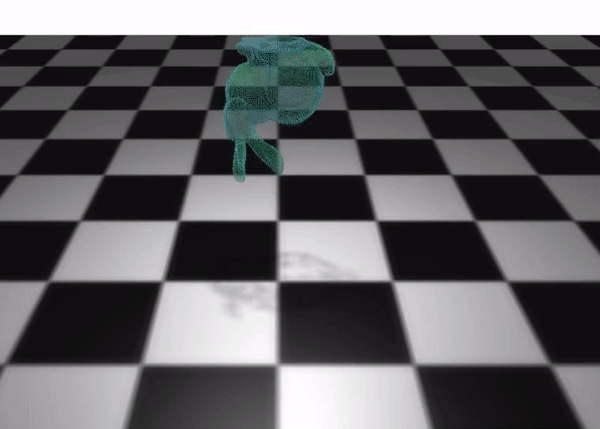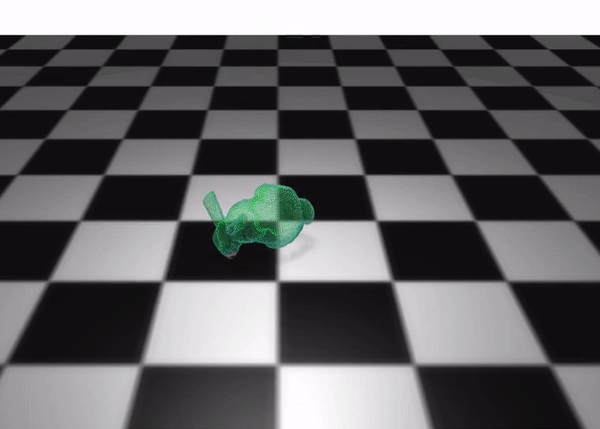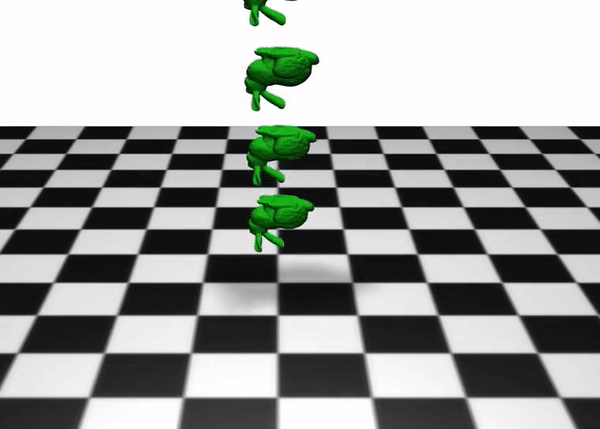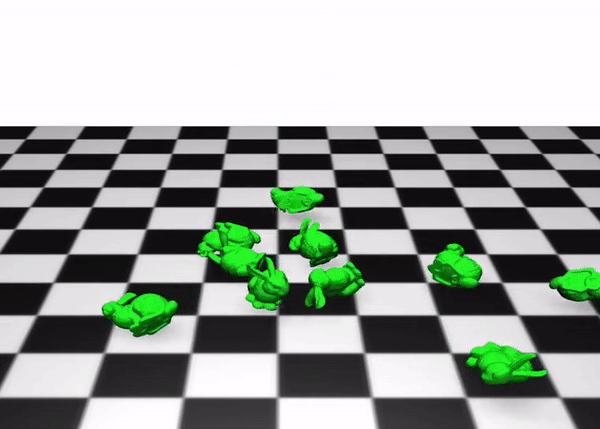
A New Fast and Robust Collision Detection and Force Computation Algorithm Applied to the Physics Engine Bullet: Method, Integration, and Evaluation. Sagardia, M., Stouraitis, T., and Silva, L.e. Conference and Exhibition of the European Association of Virtual and Augmented Reality (EuroVR), 2014, pdf, video — |
|
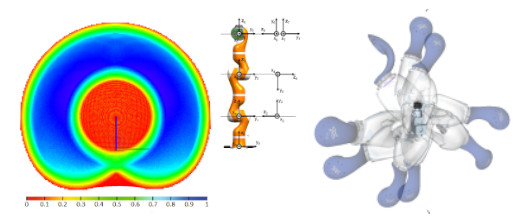
Reachability and Capability Analysis for Manipulation Tasks. Porges, O., Stouraitis, T., Borst, C., and Roa, M.A. First Iberian robotics conference, 2013, link — |
|
Intelligent Particle-Filter based Robot Localization.
Siamantas, G., Stouraitis, T., and Tzes, A. 9th Mediterranean Conference of Control and Automation, 2011, link |